
Success Cases
Explore how manufacturers use Wandelbots NOVA to plan, build, and scale robot automation.


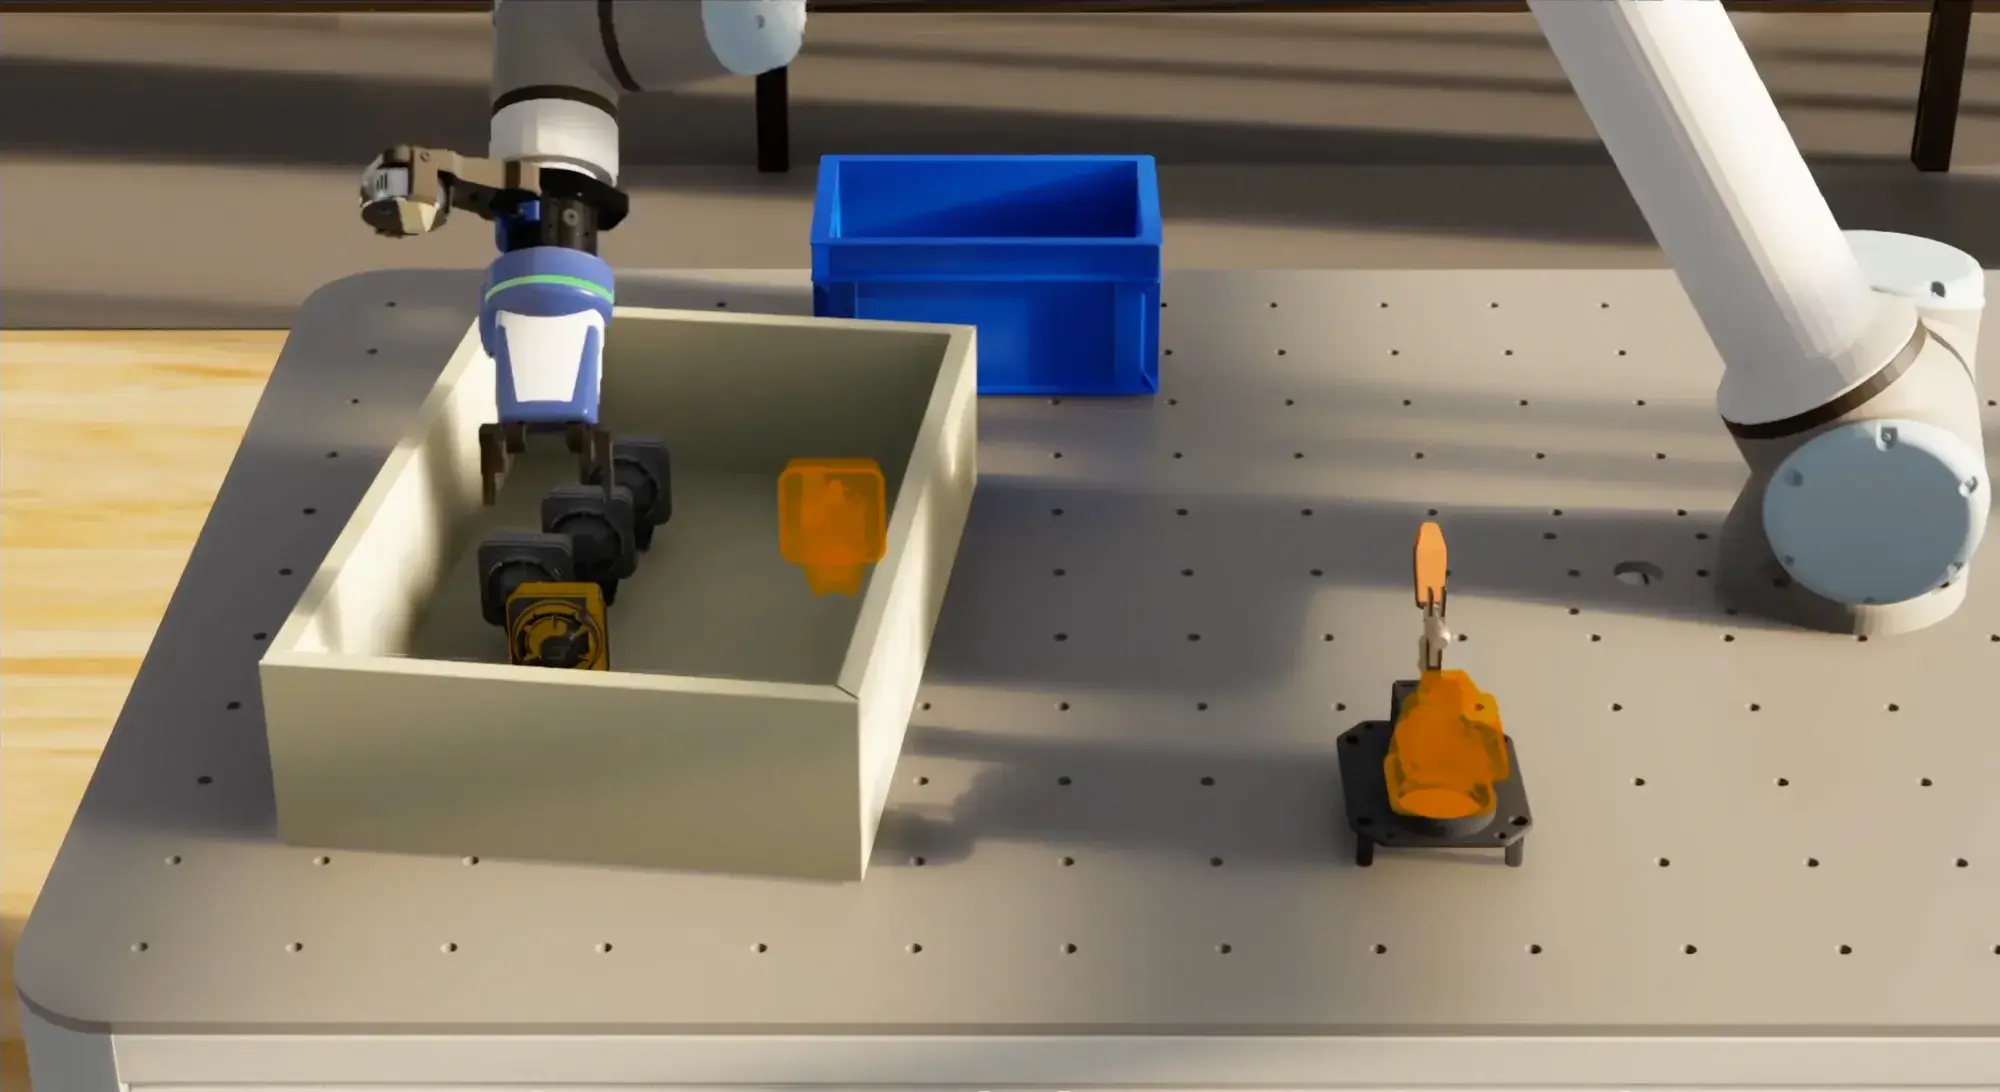
Volkswagen reduces time to market with digital planning in Wandelbots NOVA
Volkswagen uses Wandelbots NOVA with NVIDIA Omniverse to plan and simulate a dynamic pick-and-place application before physical implementation. Vision data is translated into robot movement so teams can optimize the robot, tooling, peripherals, and path behavior earlier in the planning process.
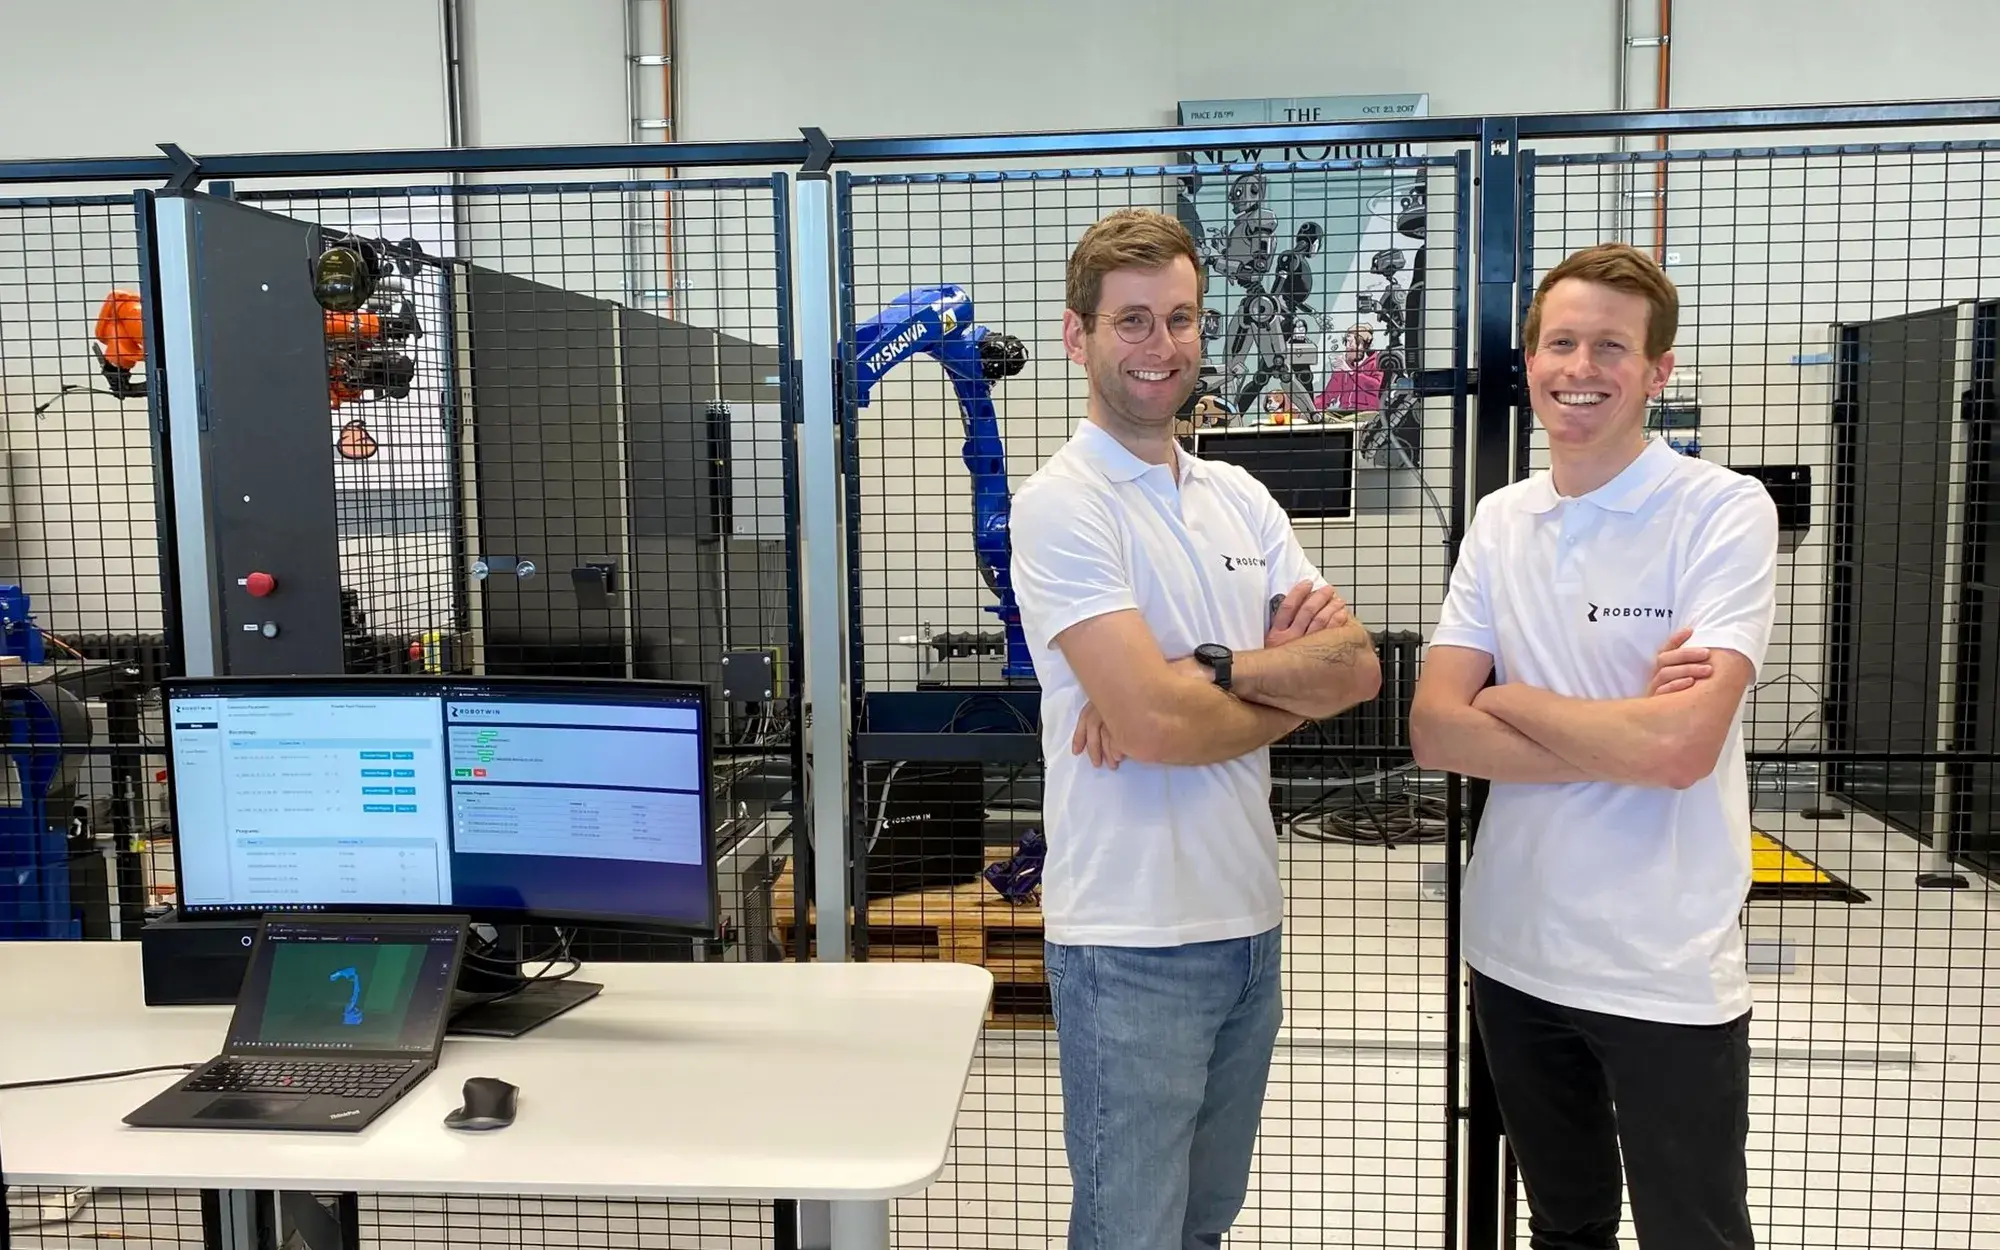
User-friendly app makes robotics surface treatment accessible to everyone
RoboTwin integrated its smart teaching device with Wandelbots NOVA so operators can teach robots by demonstrating movements. The integration helps RoboTwin support more robot systems and gives system integrators better tools for easy-to-teach surface treatment apps.
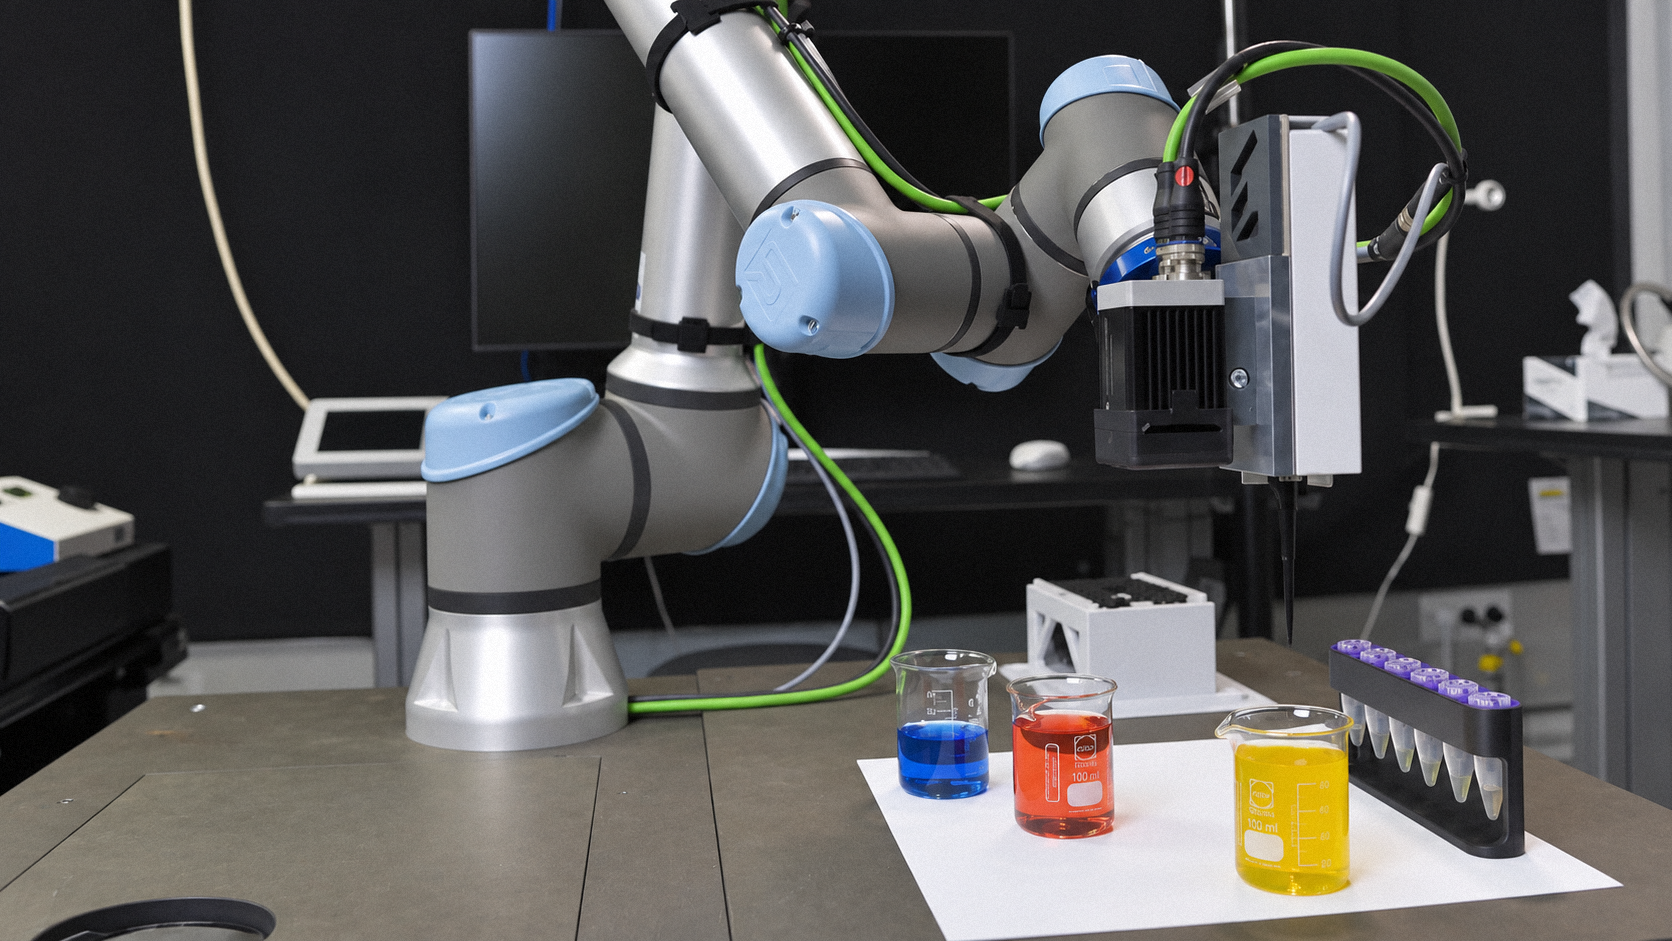
The Physics of Life Excellence Cluster of TU Dresden boosts productivity with AI-driven automation
Physics of Life at TU Dresden worked with Wandelbots and the Max Planck Institute to automate repetitive pipetting tasks. A web-based NOVA application lets researchers with limited robotics knowledge instruct a robot to perform work that was previously manual.
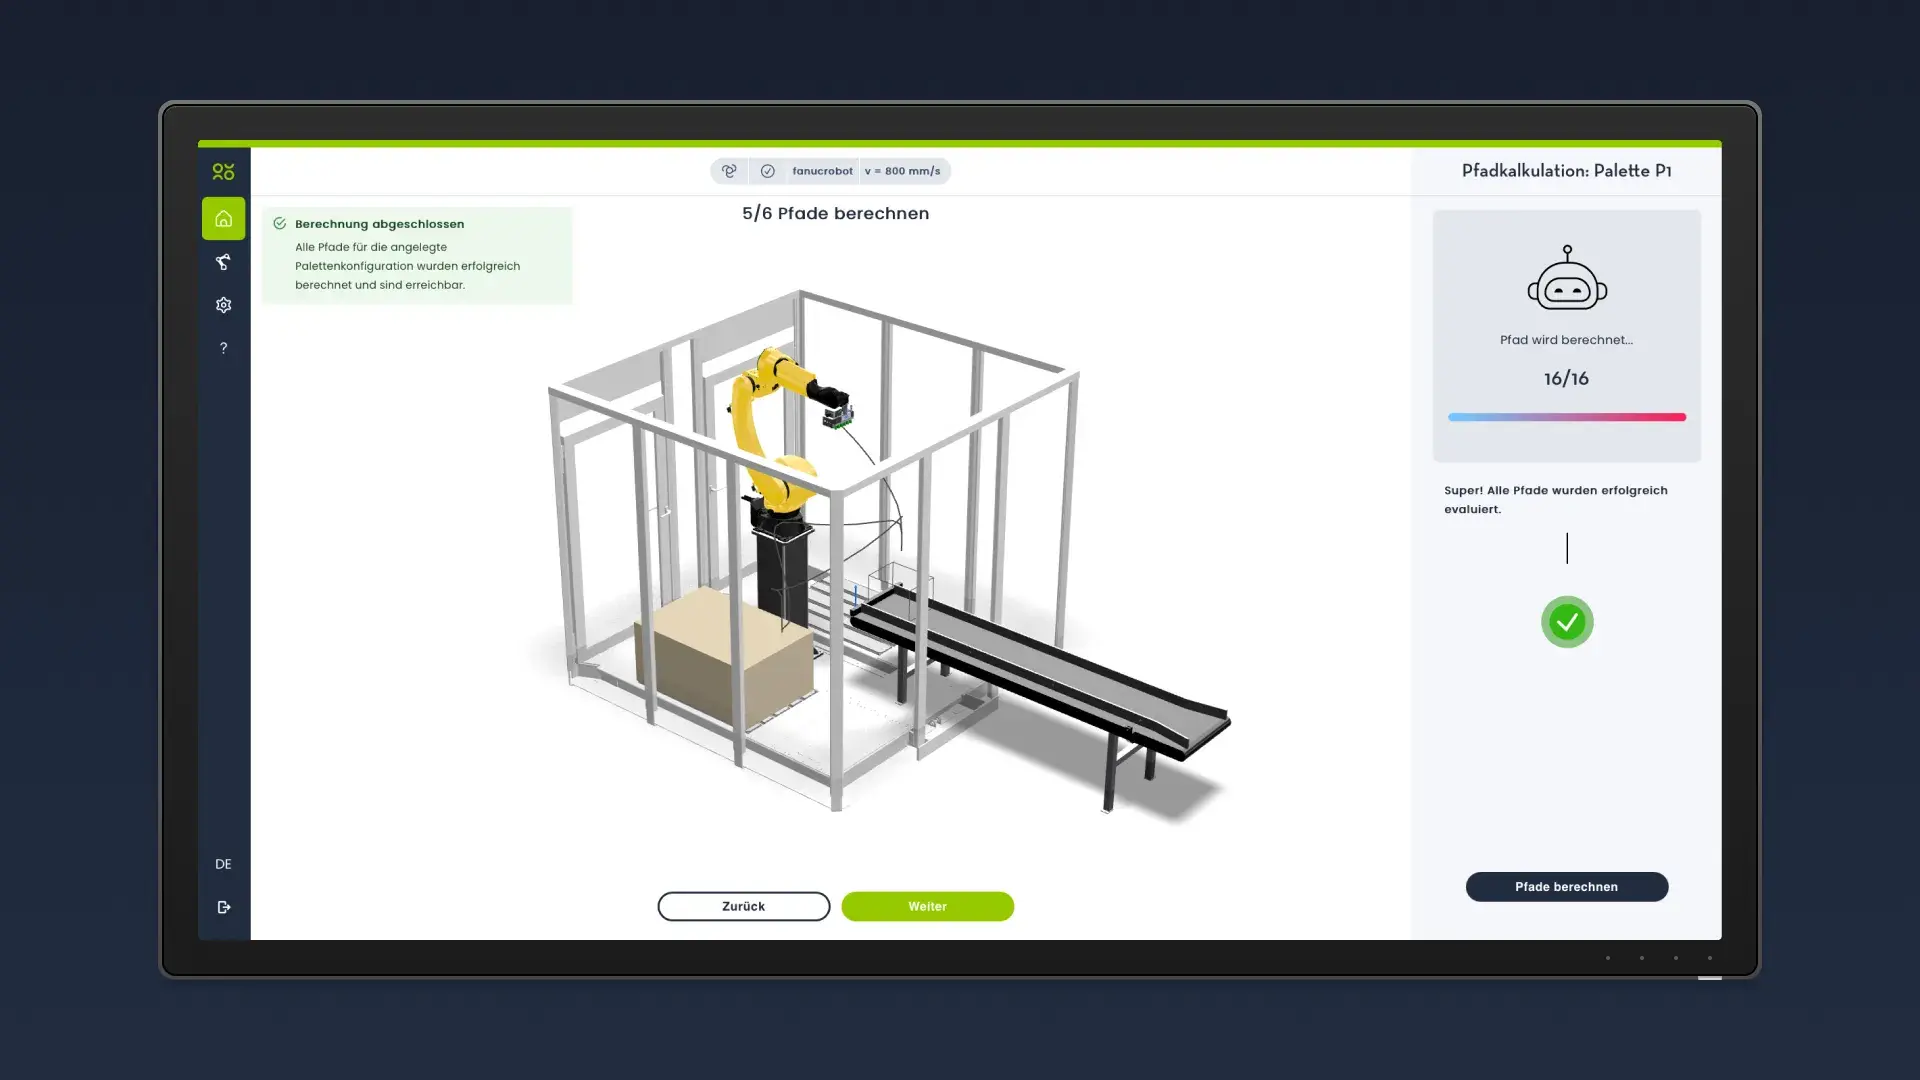
Empowering system integrators with easy automation: Self-service robotic palletizing solutions for scalable growth
Coboworx uses Wandelbots NOVA to make robotic palletizing easier to access through a Robotics as a Service model. The application generates collision-free paths through an intuitive interface and reduces dependency on specialized robot engineers.
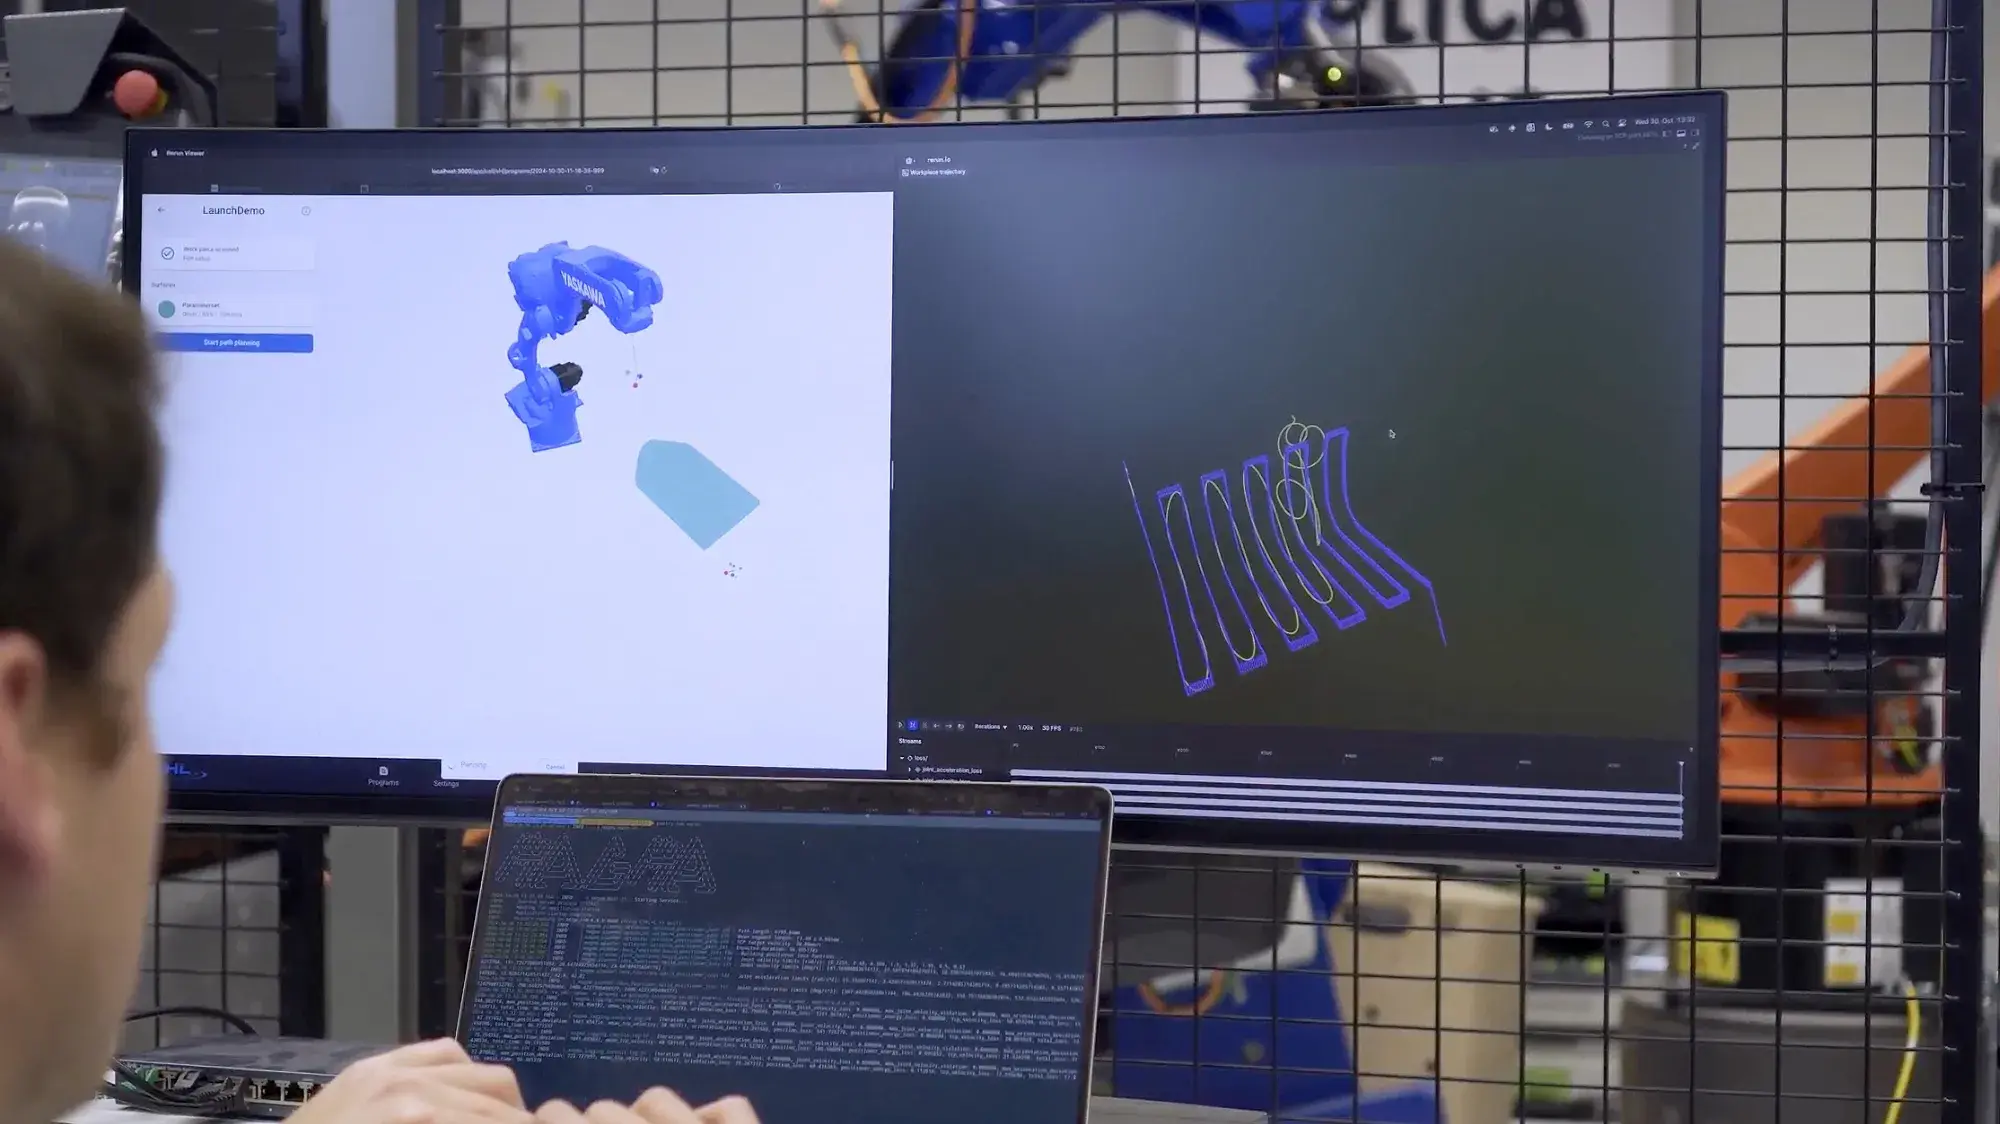
How SHL is expanding the surface treatment market with Wandelbots NOVA
SHL partnered with Wandelbots to develop a custom surface treatment application on NOVA. With an easy interface and automated path generation, SHL makes robotic grinding, polishing, and deburring more accessible for high-mix, low-volume manufacturers.
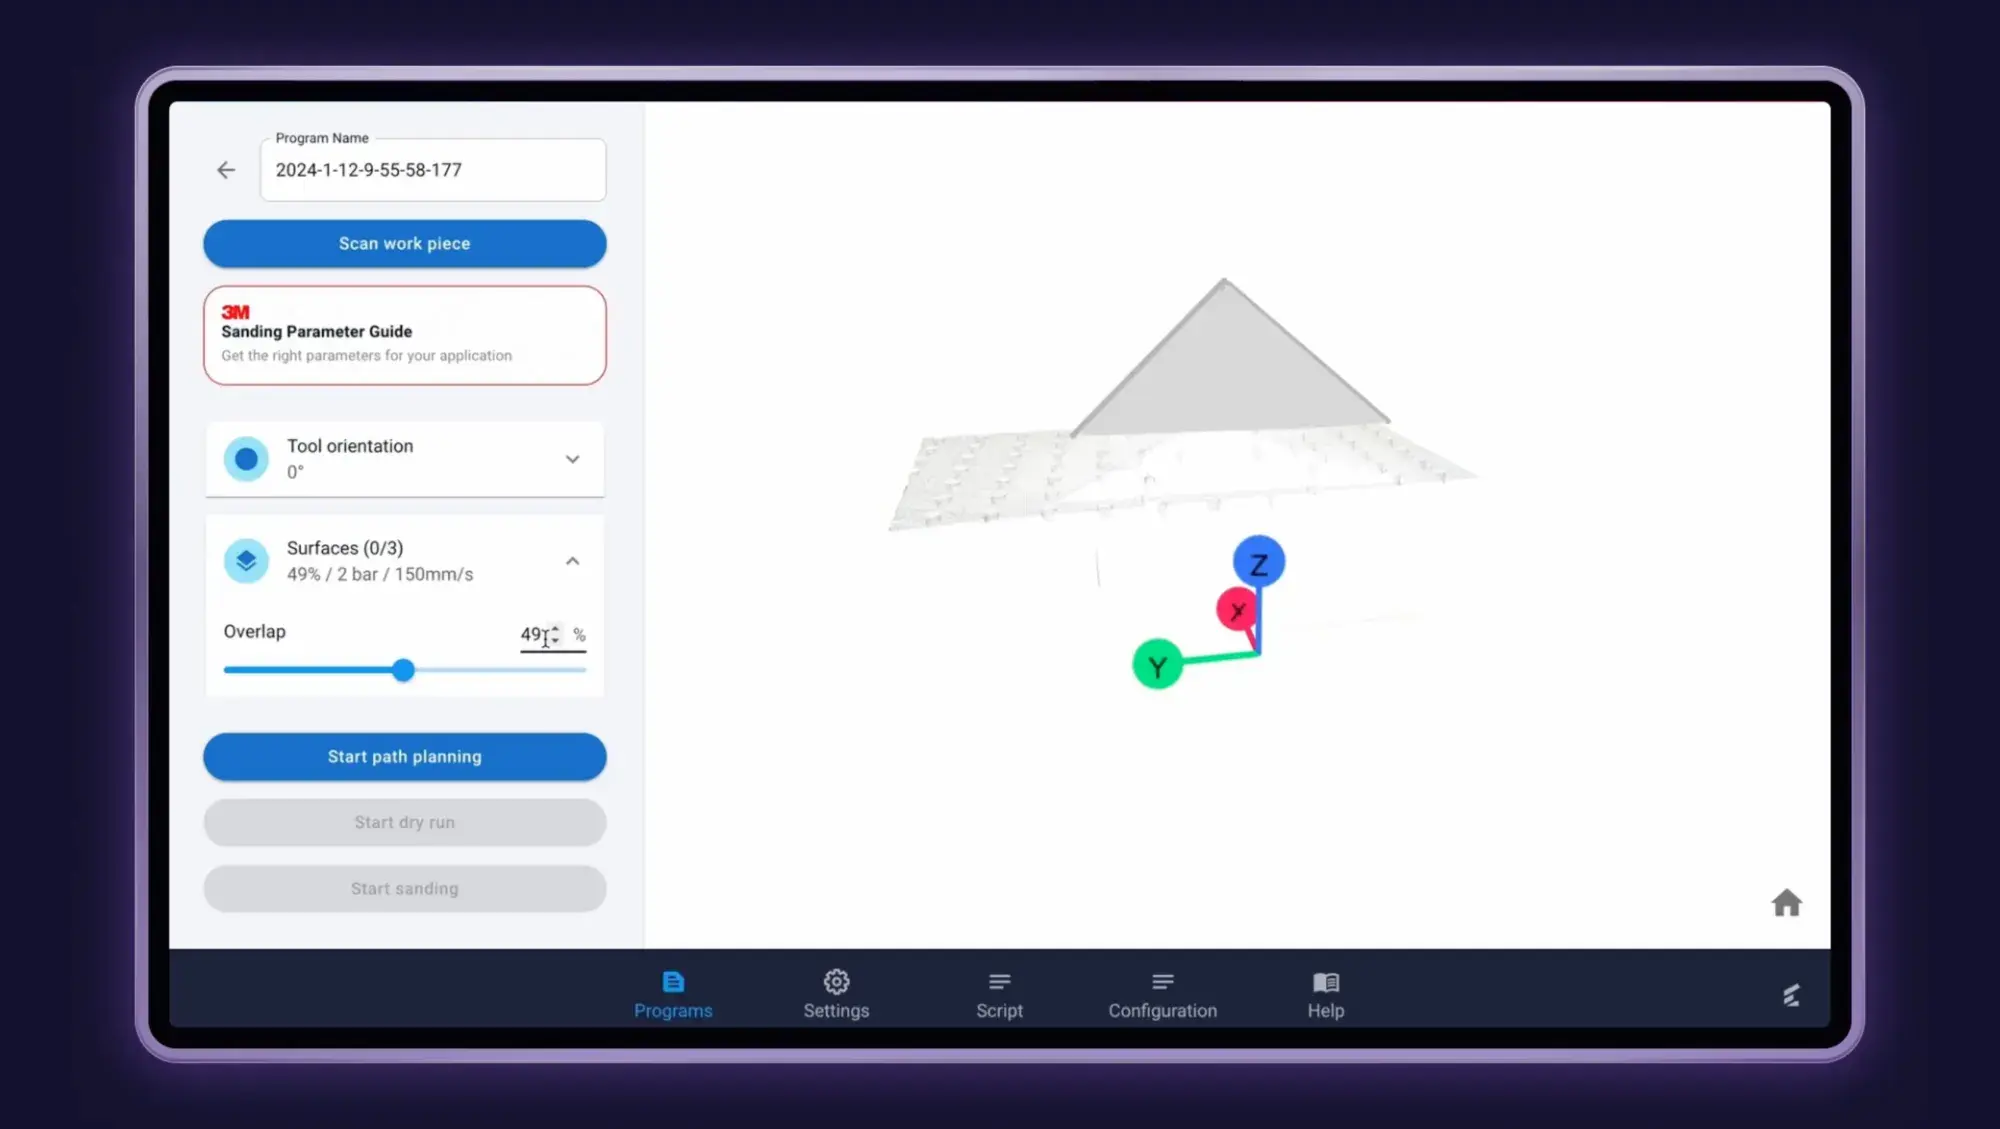
3M makes abrasive automation accessible with process expertise and a simple UI.
3M makes its extensive abrasive process knowledge accessible with NOVA, where experts can input parameters and desired final states to generate robot paths and programs automatically.