Leads the research framework and helps define the capabilities required for future battery disassembly systems.

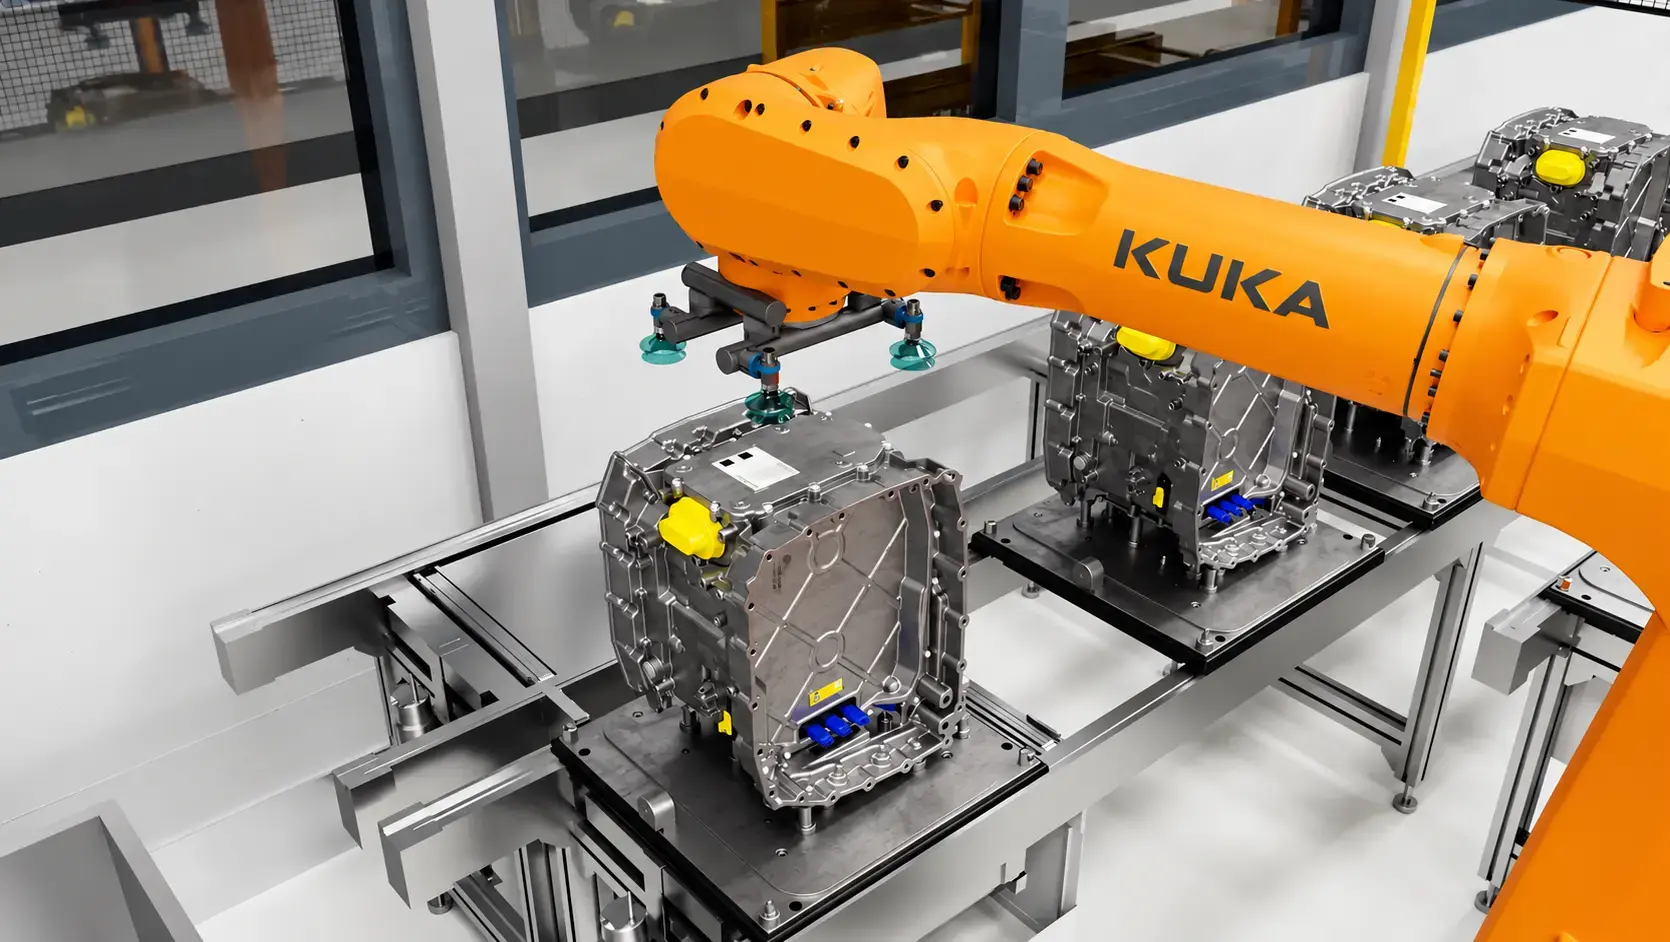
Together with Fraunhofer IWU, EDAG and Grid Dynamics, Wandelbots elaborated the simulation and physical execution for a high-voltage battery disassembly that uses vision, simulation, and adaptive robotics to identify, plan, and execute disassembly tasks on battery packs that vary in condition, geometry, and placement.
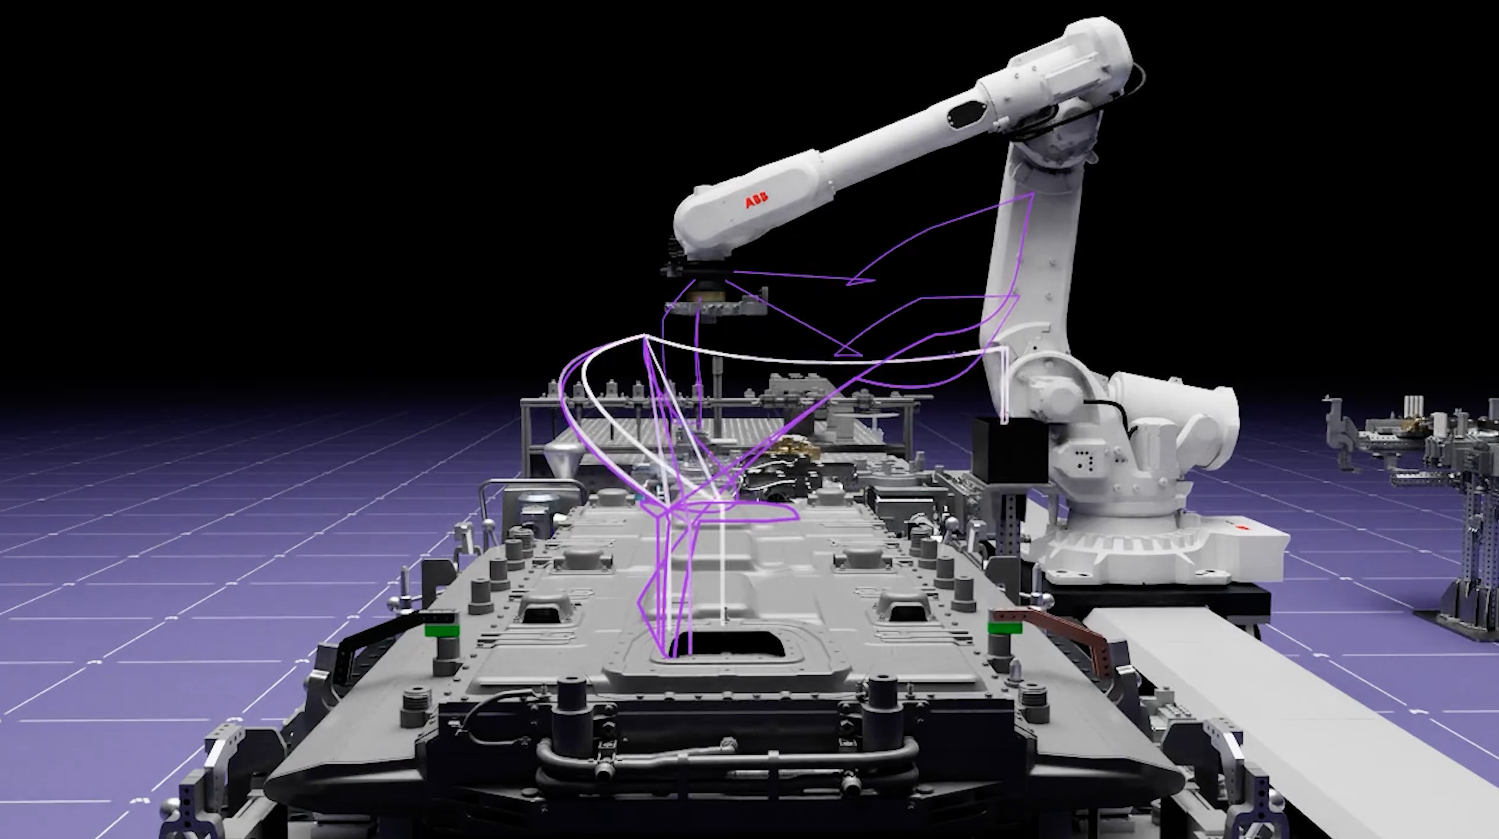
Battery disassembly is one of the most complex tasks to automate. Robots must perform numerous coordinated operations, from locating components and switching tools to cutting and unscrewing, while adapting to real-world conditions.
To address this challenge, the team developed and validated the entire workflow in simulation before deployment by combining machine vision, simulation, and software-defined automation.
The team created a high-voltage battery disassembly cell capable of planning and executing complex disassembly processes with greater flexibility and adaptability.
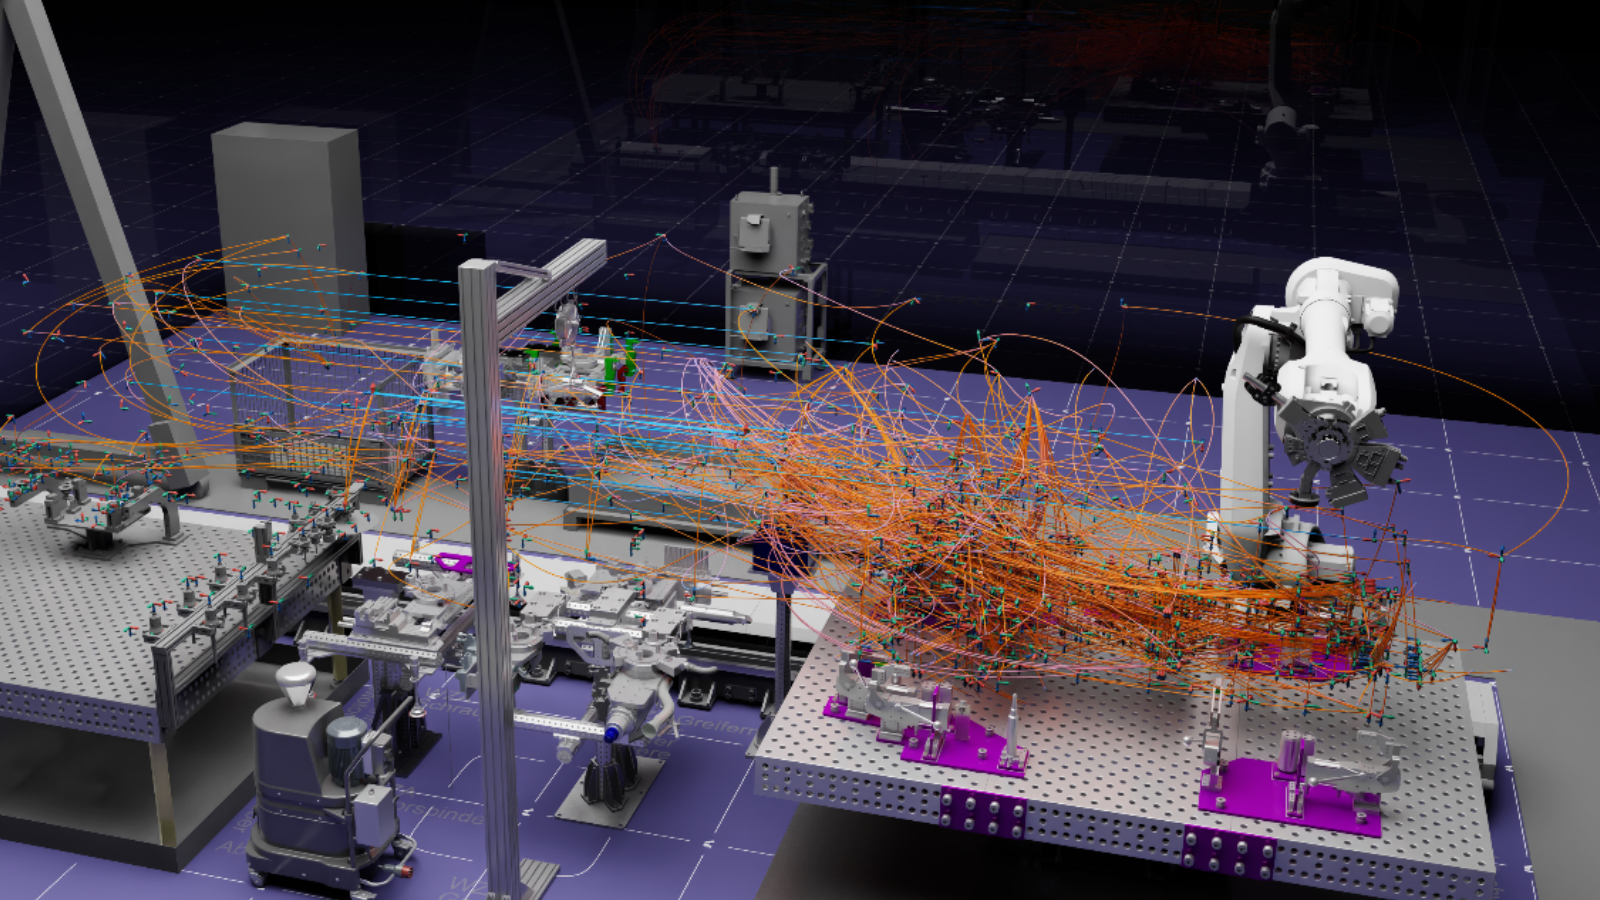
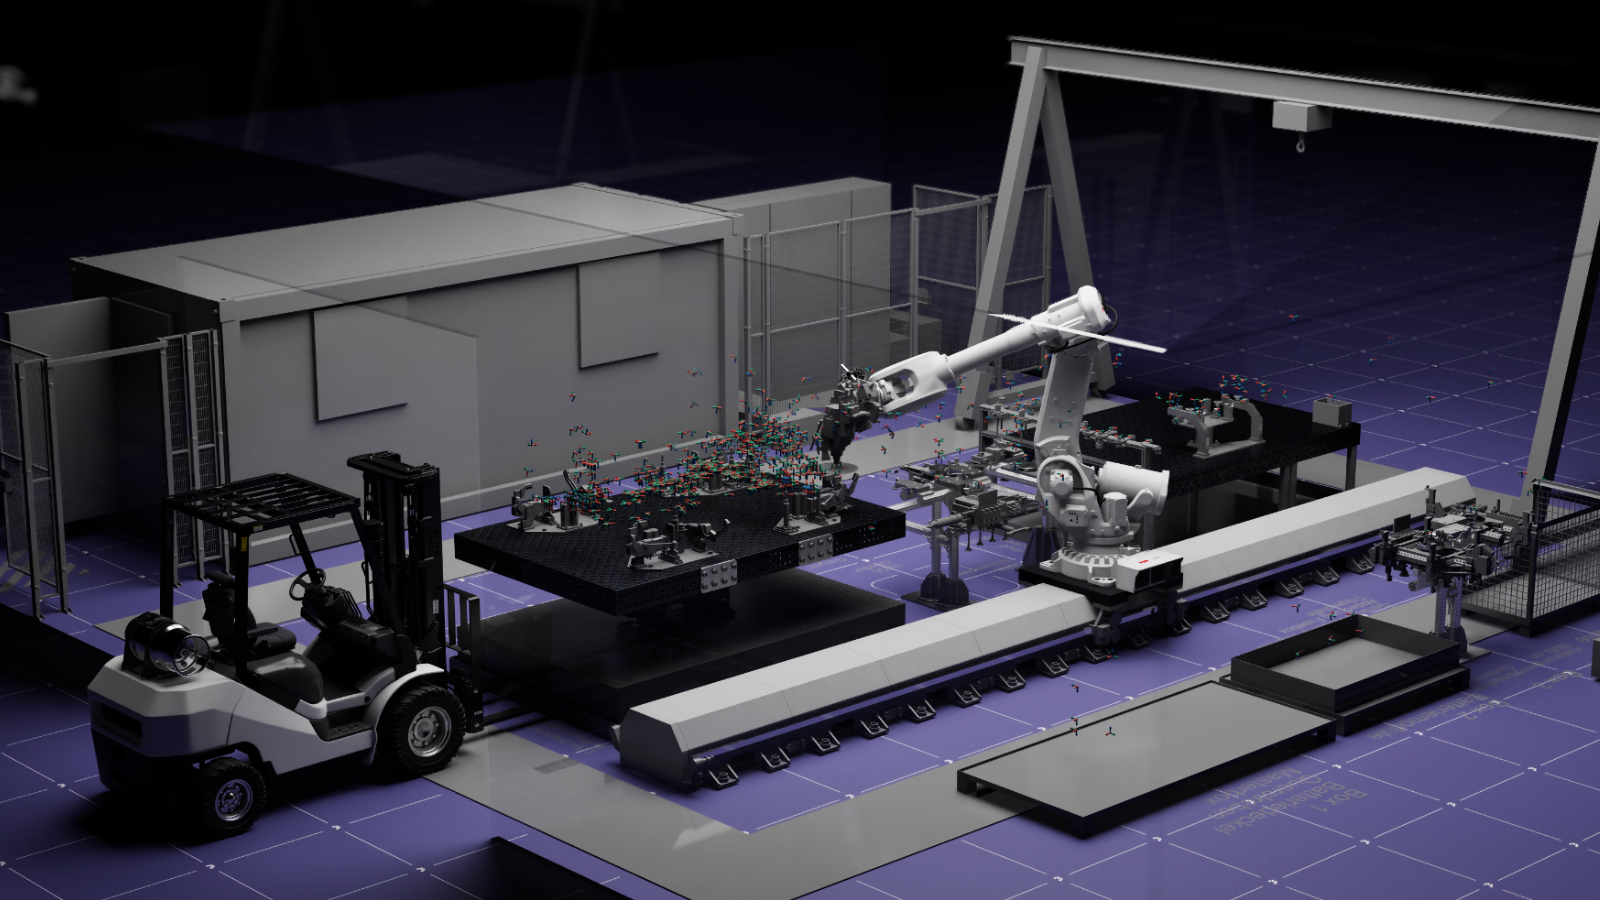
The objective is not to automate the disassembly of a single battery pack, but to investigate how future disassembly systems can handle complex robotic workflows across varying battery designs.
The project focuses on enabling robots to adapt their actions based on vision input and AI policies, rather than relying on fixed programming.
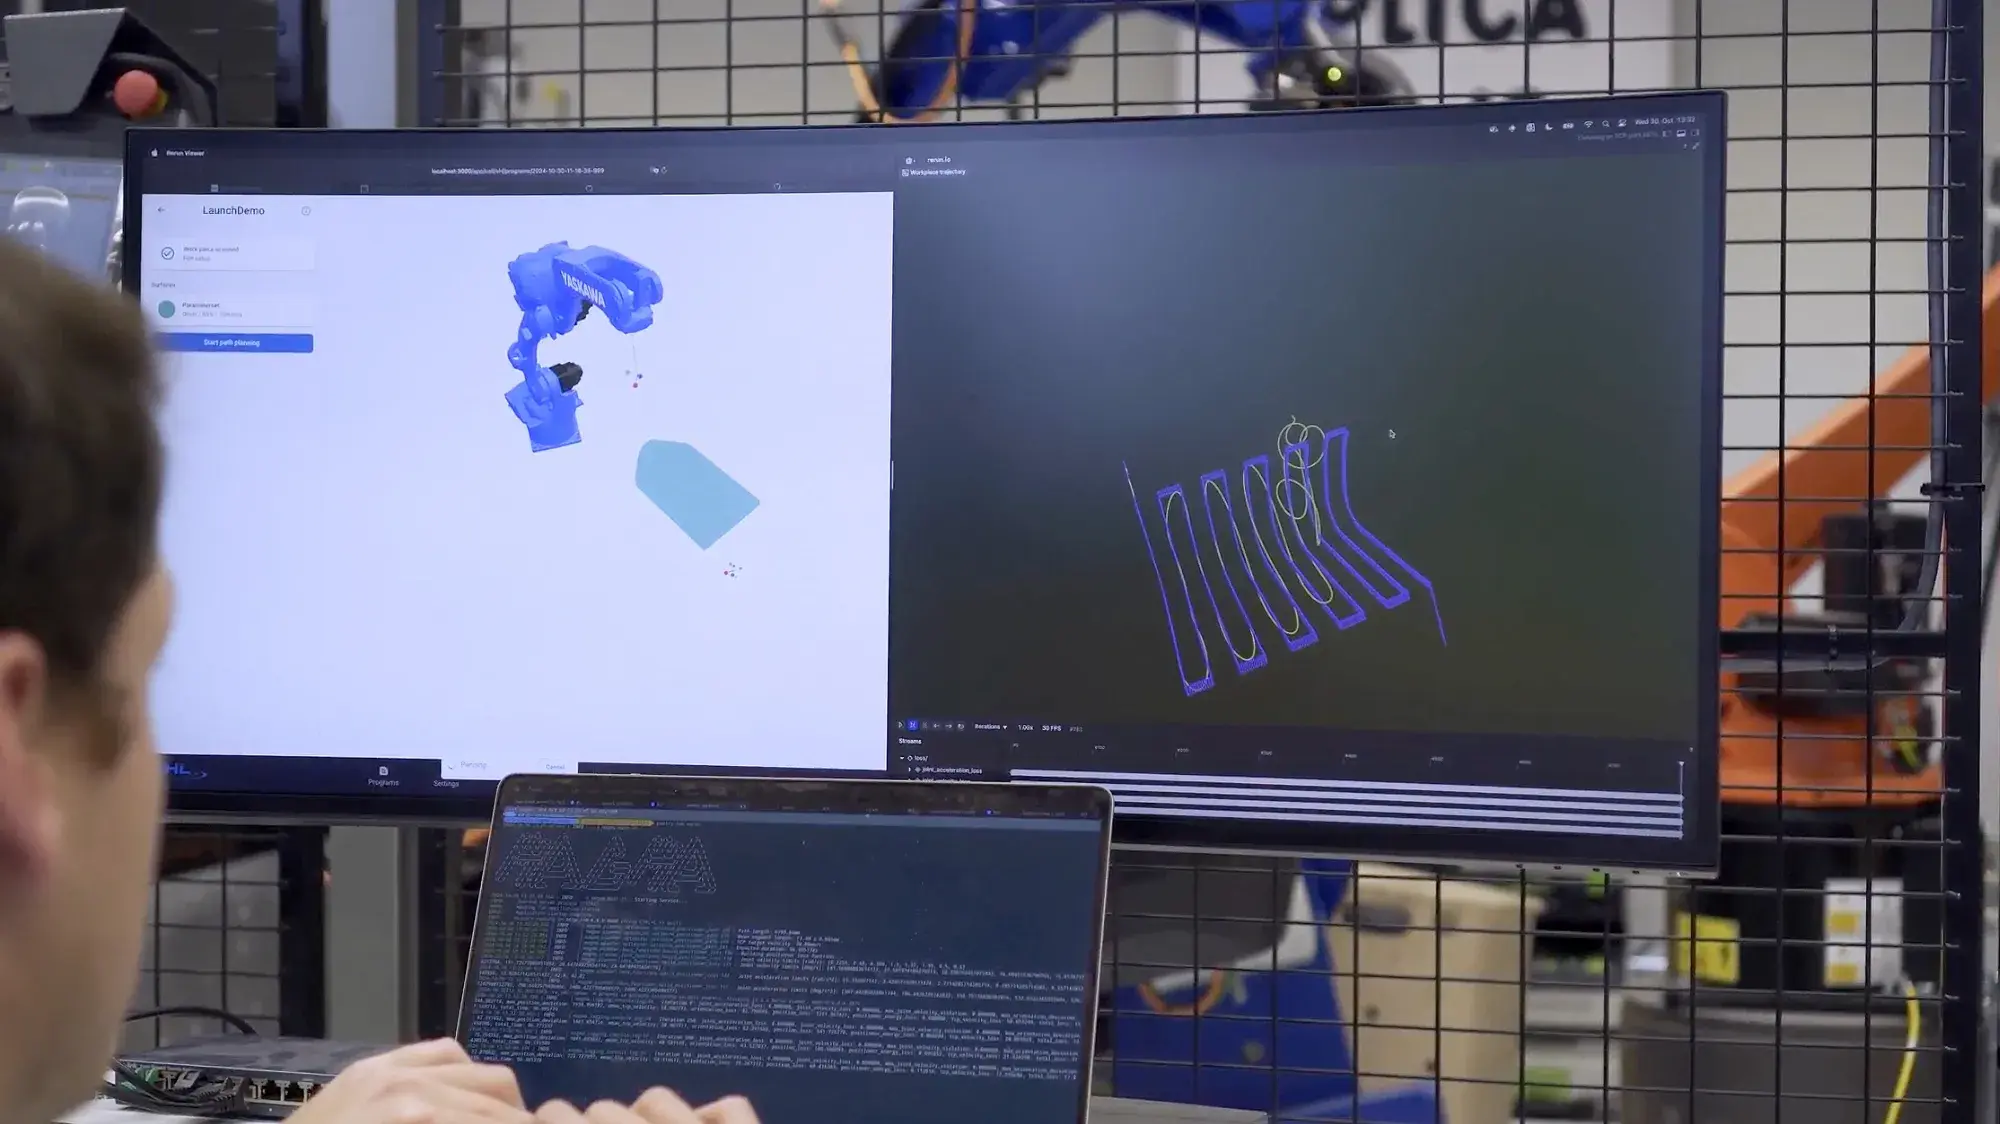
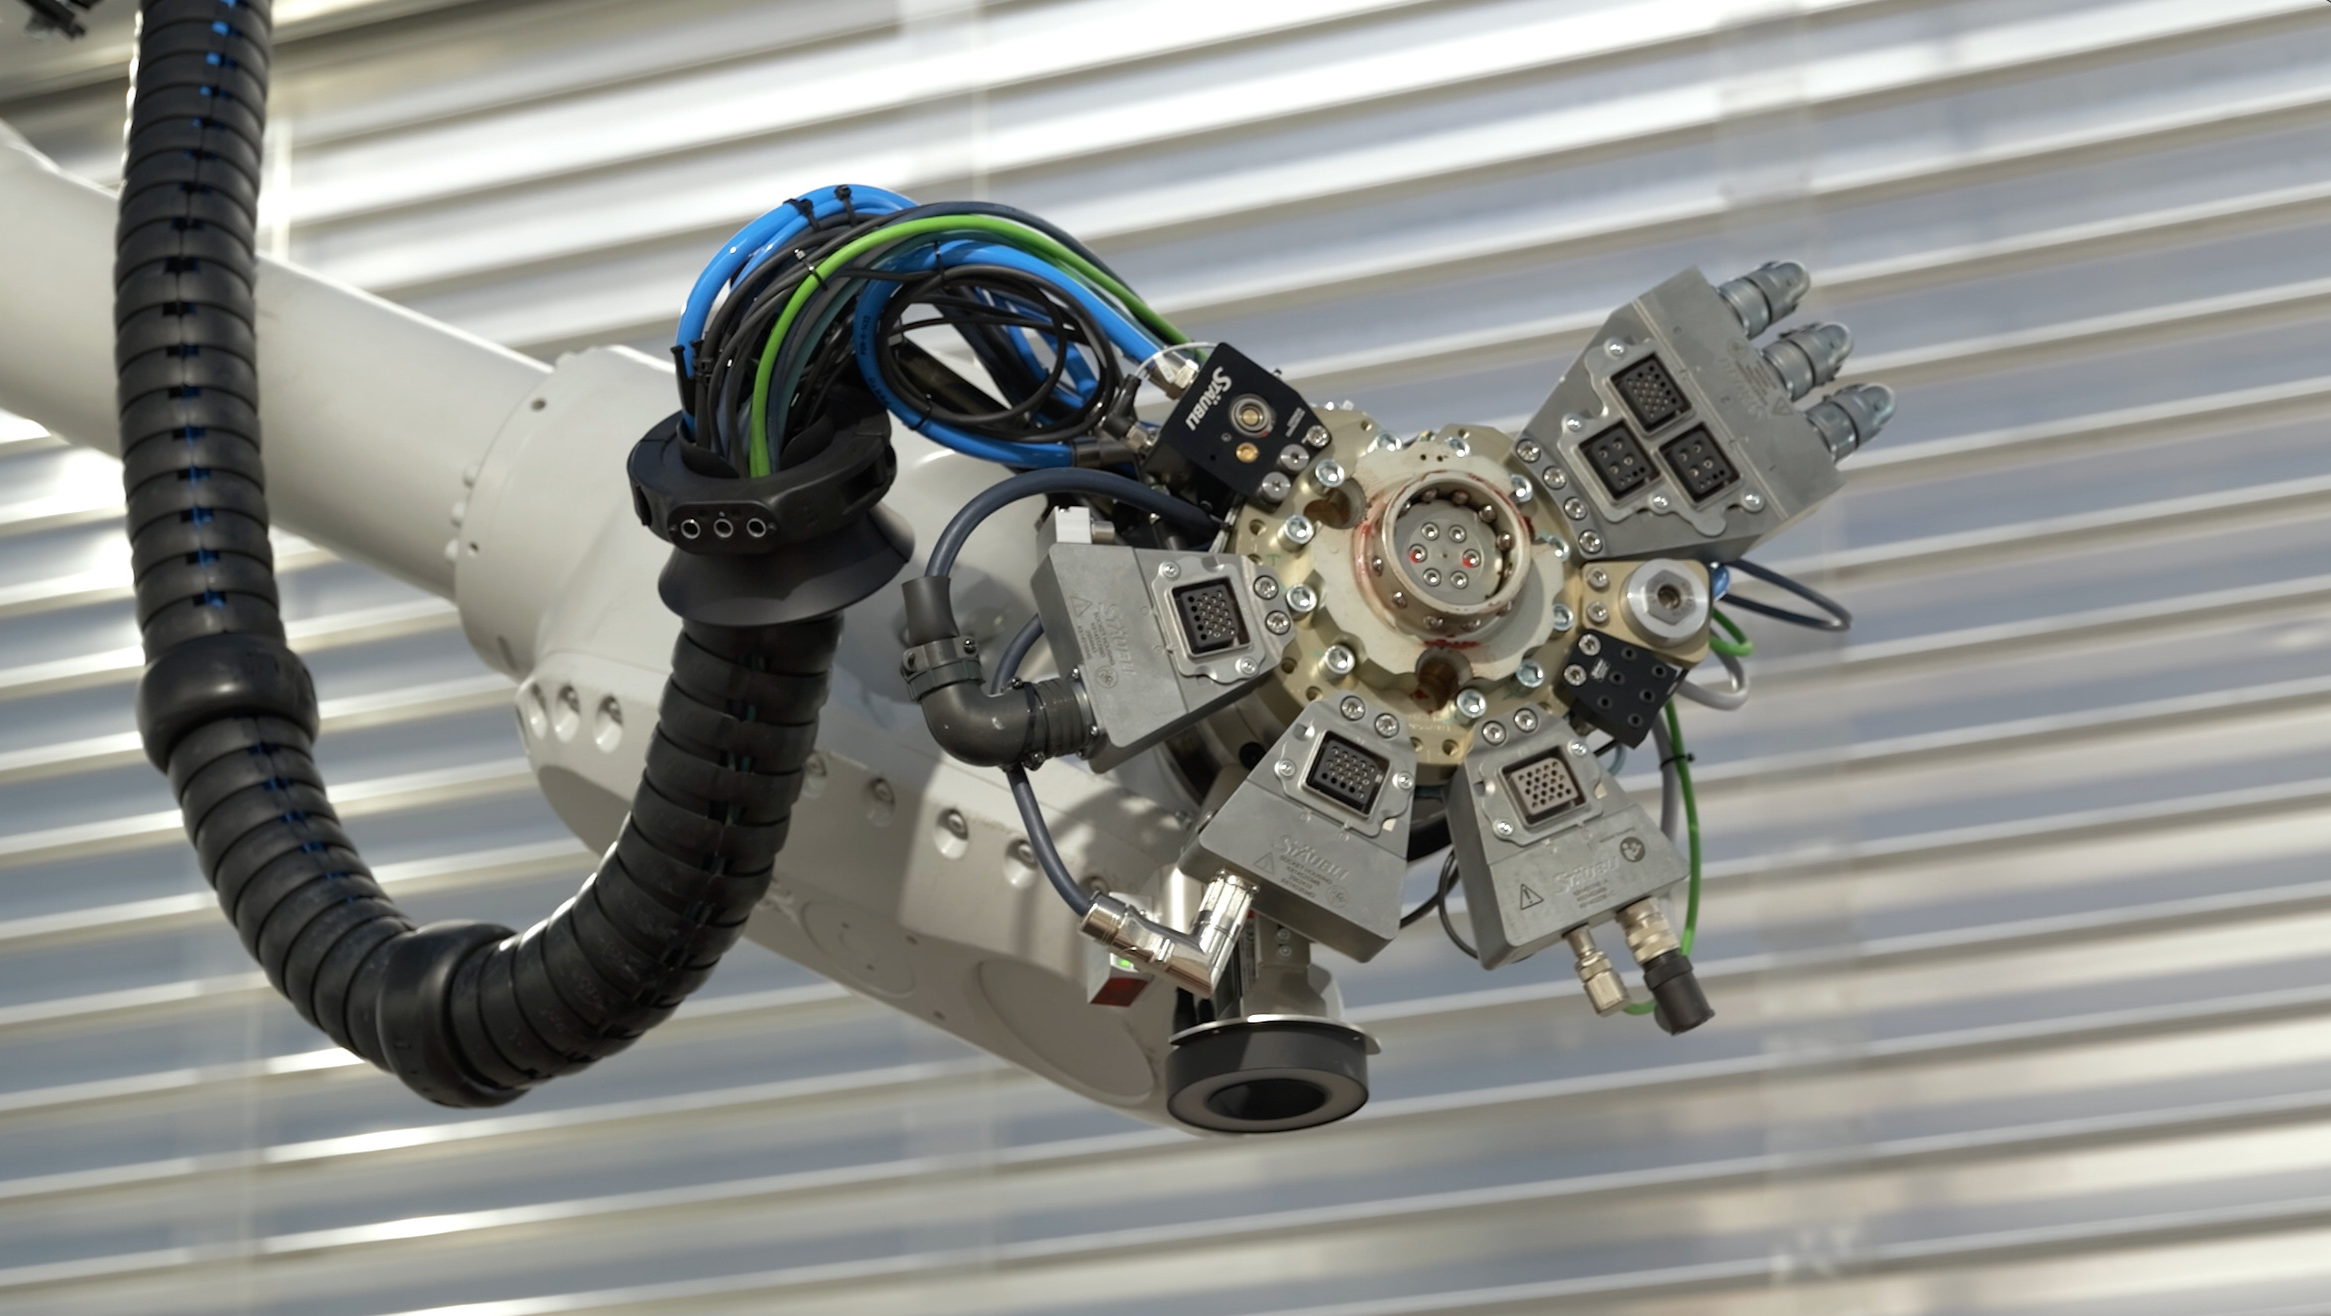
The team combined Wandelbots NOVA, NVIDIA Isaac Sim, machine vision, and adaptive motion planning to create an intelligent battery disassembly system.
The solution can locate components and perform key tasks such as lifting, cutting, and unscrewing. A single robot operates with 16 tool configurations and an 8-meter linear rail, enabling flexible operation across the work area.
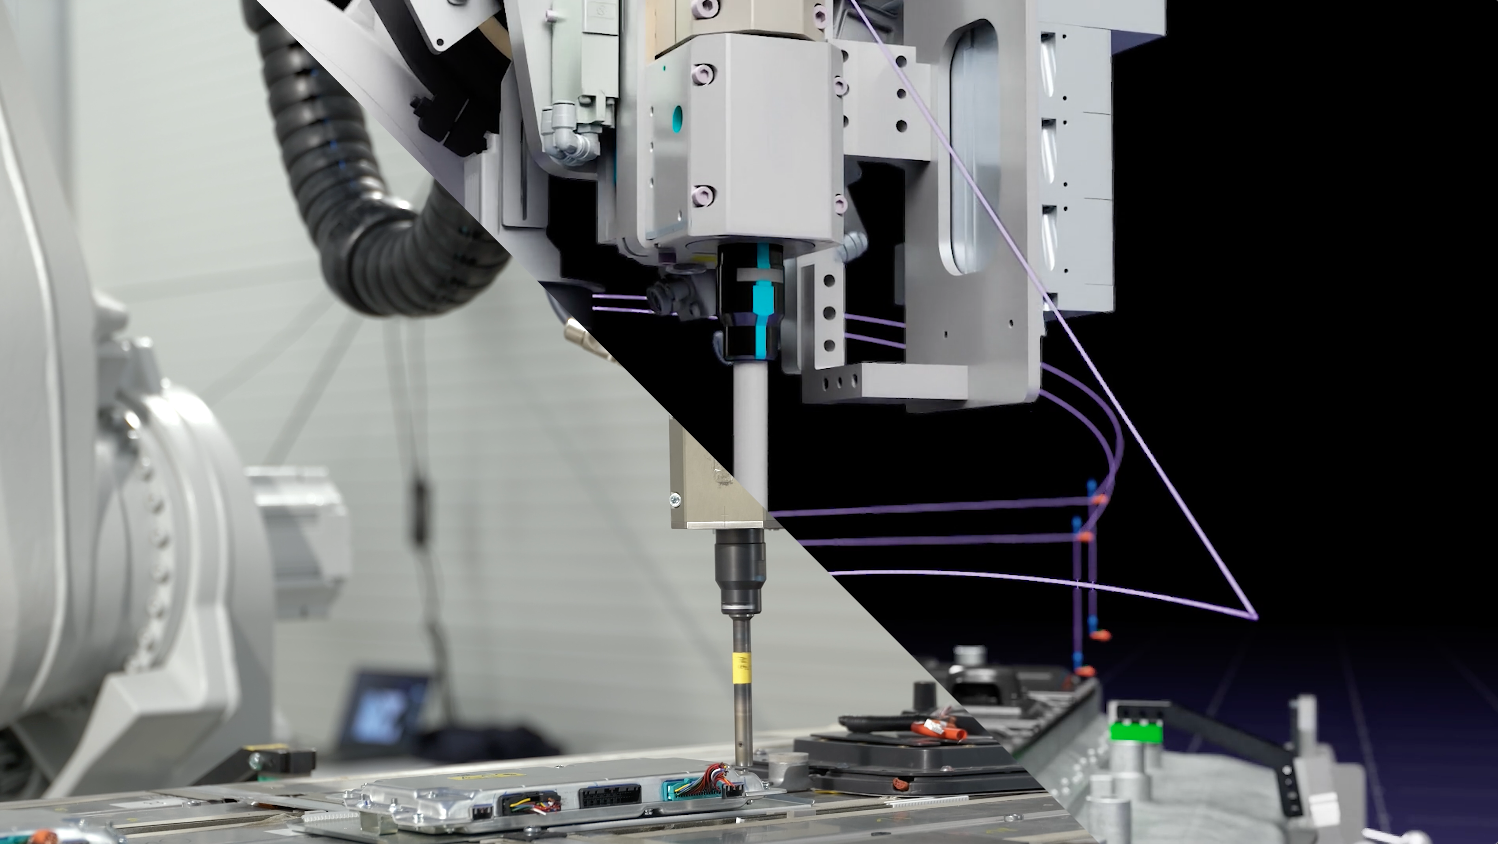
Every battery pack is different, making disassembly a challenge that combines real-world variability with complex robot workflows. To address this, the project uses vision, simulation, and adaptive motion planning to create a more flexible automation approach.
A simulation-first workflow allows robot programs and processes to be developed, tested, and validated before deployment on the physical cell.
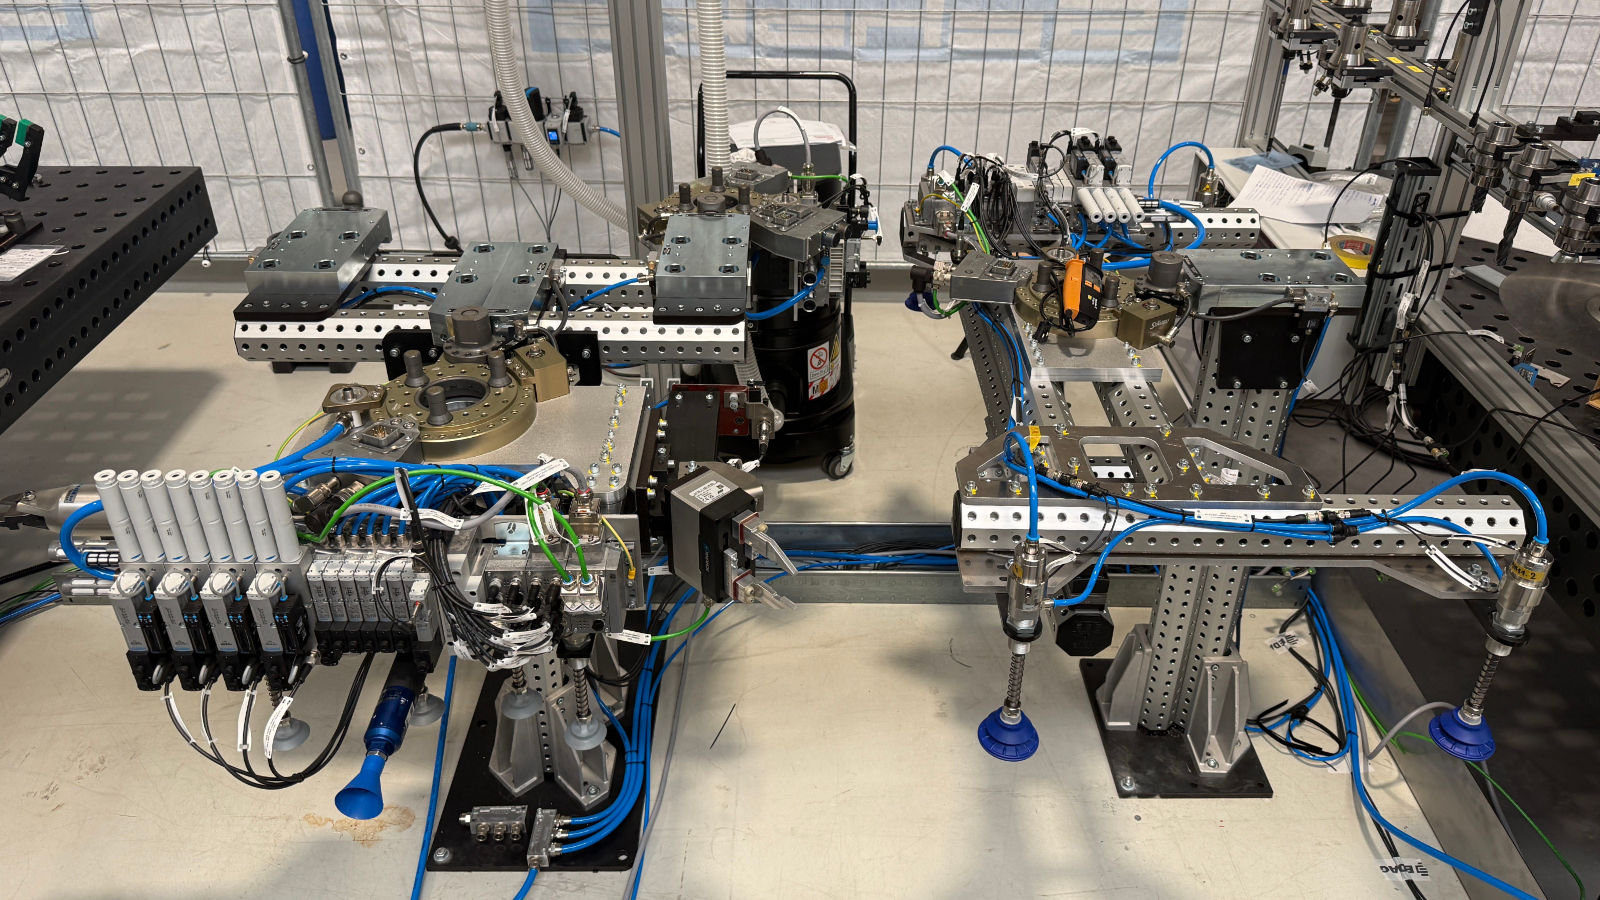
The use case provides a blueprint for how complex robotic disassembly processes can be designed, simulated, and validated before deployment.
With the battery disassembly cell now built, the work moves into the next phase of real-world testing and evaluation. The objective of the project was not to demonstrate a production-ready outcome, but to investigate how vision systems, simulation, and software-defined automation can be combined to address the challenges of battery disassembly.
Talk to our team about how Wandelbots NOVA can help you scale robot automation faster.
Get in touch →